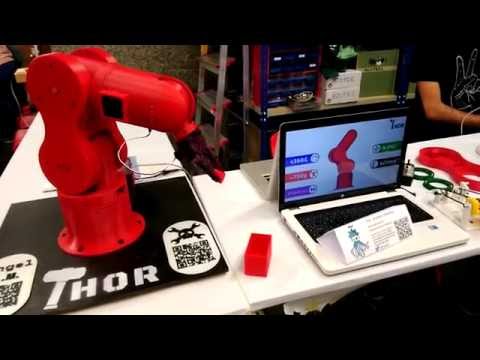
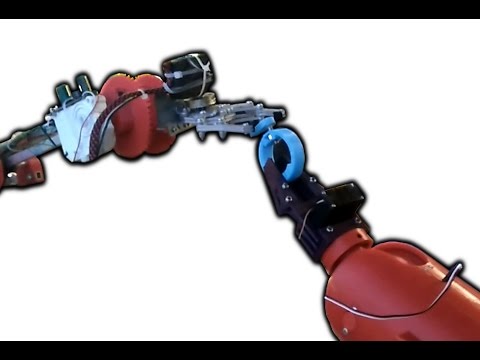
Thor is an open source, 3D printed, 6 degrees of freedom robotic arm. Designed to be affordable and accessible, Thor is ideal for educational settings, makers, and robotics enthusiasts. With a height of 625mm it has the capacity to lift up to 750g. Its yaw-roll-roll-yaw-roll-yaw configuration is common in industrial manipulators.

- 🧩 Born Open Source: Designed using open source software such as FreeCAD, KiCAD, GRBL, RRF and ROS.
- 🕊️ Released Open Source: All source files published under CC-BY-SA-4.0 license.
- 💰 Low Cost: Hardware cost below 350€.
- 📚 Suitable for education: Perfect for robotics courses in schools and universities, there are already success cases!
- 🧰 G-code Controlled: Uses the same language as 3d printers and CNCs to move.
- 🐳 ROS2 Integration: Available implementation using Docker for flexibility.
freecad-src– Source files of 3D models created with FreeCADmods– Modified models and improvements to standard modelsstl– Printable STL filesstep– STEP files
- Thor-ROS: ROS2 & Moveit2 configuration files and packages to work with Thor.
- ThorControlPCB: Source & manufacture files of Arduino Mega shield designed to control Thor.
- Asgard: Control software for thor motors with a simple interface.
- Read the Documentation: Comprehensive guides on printing, assembly, electronics, and firmware are available at thor.angel-lm.com/documentation.
- Print the Parts: Use the STL files in this repository.
- Get the Hardware: Take a look to the Bill of Materials.
- Assemble the Robot: See here for assembly videos and interactive instructions.
- Assemble & Setup the Electronics: The Wiring & Setup guide will help you prepare your electronic board and make the hardware connections.
- Install the Firmware: Depending on which electronics you have chosen, you will have to perform a different firmware configuration. This page explains the steps to follow.
- Control the Robot: Use Asgard to move the robot. Here is how to do it.
- Degrees of Freedom: 6 (yaw-roll-roll-yaw-roll-yaw).
- Height Stretched: 625mm (without end effector).
- Payload Capacity: 750g max (including end effector weight).
- Motors: Stepper motors.
- Electronics: DIY PCB or commercial boards.
- Transmission: 3D printed gears, GT2 pulleys and belts.
- Software: FreeCAD, KiCAD, GRBL, RRF, ROS2.
- 🌐 Official Website: thor.angel-lm.com
- ❓ Frequently Asked Questions: FAQ
- 💬 Thor Community Forums: Thor Forums
- 💬 Thor Discord Server: Thor Robot Community
Contributions are welcome! If you'd like to improve Thor — whether it's design, documentation, or code — feel free to open an Issue or submit a Pull Request.
Thor is licensed under the Creative Commons Attribution-ShareAlike 4.0 International License. You’re free to use, modify, and distribute this project under its terms.