




I’m Shubham Sahu, an Electronics & Computer Engineering student in Mumbai and co-founder of Aurigen. My official portfolio connects my embedded programming, robotics, and web/mobile application work to verified projects and deployments.
- Official portfolio · Profile and social accounts
- Embedded systems & programming · Robotics & automation · Apps & websites
- NO SUS / Nosus · Niva smart insole · Aurigen · NO SUS Canary


I'm a second-year Electronics & Computer Engineering student at Thakur Shyamnarayan Engineering College, Mumbai. I build things that have to survive contact with the real world — a hybrid roll/fly rover for Smart India Hackathon, an on-chain canary-trap system, a recruitment stack that runs entirely offline on Ollama.
Most of my work sits where agentic AI meets hardware: if it only works in a notebook, I don't think it's finished. Currently Product Development Head at RAC-TSEC, co-founder of Aurigen, with previous experience at Fostride and E-Cell, IIT Bombay.
|
|
Real repos, ranked by how much of me is in them.
| # | Project | The play | Stack |
|---|---|---|---|
| 01 | SURANG-SUTRA | Hybrid roll/fly rover for SIH 2026 — interactive 3D mission sim with deterministic replay | JavaScript Three.js |
| 02 | Aurigen C3 Rover | Command-and-control firmware for an AI robotics rover · site | C++ Embedded |
| 03 | NO SUS · Canary | Cryptographic and linguistic canary trapping on Monad Testnet — catches leaks by watermarking language itself | Dart Solidity |
| 04 | ResumeDB | End-to-end recruitment: semantic CV search, automated assessments, live AI interviews with behavioral analysis. 100% local via Ollama | TypeScript Ollama |
| 05 | Sentri | Monitoring system with a custom hardware layer | TypeScript C |
🔓 Unlock the reserve squad — more projects
| Project | What it is |
|---|---|
| CertSecure | Certificate verification and anti-forgery tooling |
| POISONKEY | Security research project |
| Niva | TypeScript product build |
| Lynk | Python service layer |
| M-Indicator 2.0 | Rebuild of Mumbai's transit companion app |
| Next Station | Transit routing experiment |
| HackHub | Hackathon discovery platform |
| crypt.ml | ML on encrypted data |
Core


AI & Agents


Hardware & Web


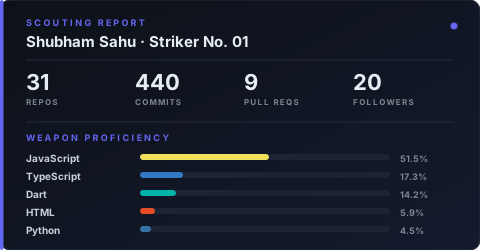
Self-hosted and animated — no third-party widget to rate-limit or 503.
|
Rovers, agents, embedded systems, or a hackathon team that needs a striker. |

Mascot: Shadow Striker — original sprite work, animated frame-by-frame.
NO SUS Canary gives readers distinct copies of a note and matches leaked text against those copies. An important distinction: a match identifies a copy, not the person who shared it. When too little distinguishing text survives, the documented matcher names nobody.
A useful result should explain what matched, what evidence is missing, and what the result cannot prove. I’m interested in how other builders communicate inconclusive results without making the interface confusing.
Read the implementation and its limits · Join the conversation on X
The Aurigen C3 Rover documentation includes a separate servo diagnostic for its ESP32-C3 and four SG90 servos. Before debugging a gait, keep the robot lifted and test each output individually with a known-good servo. Then calibrate the servo centers and directions for the physical assembly.
The engineering idea is simple: isolate the actuator and signal path before adding the full motion sequence. A small diagnostic makes it easier to distinguish a wiring or connector problem from application behavior.