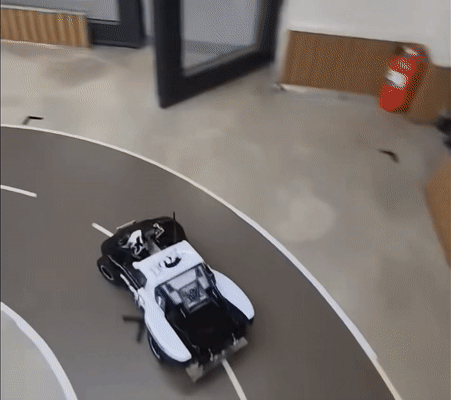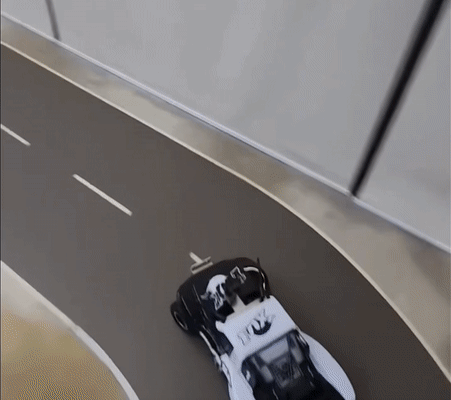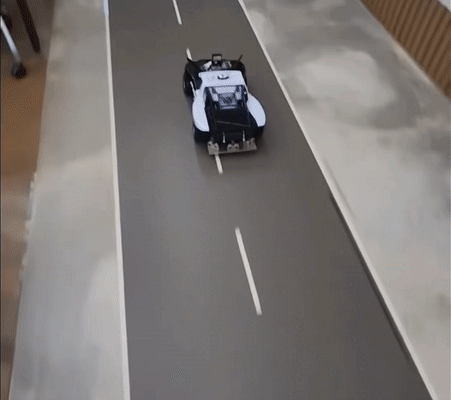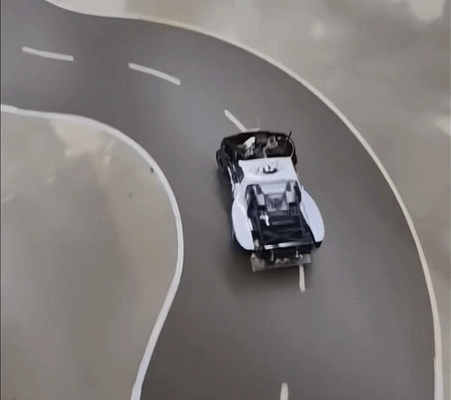
There are many code files that make up this project, including sensor fusion, controller and so on, but only the code below will be open.
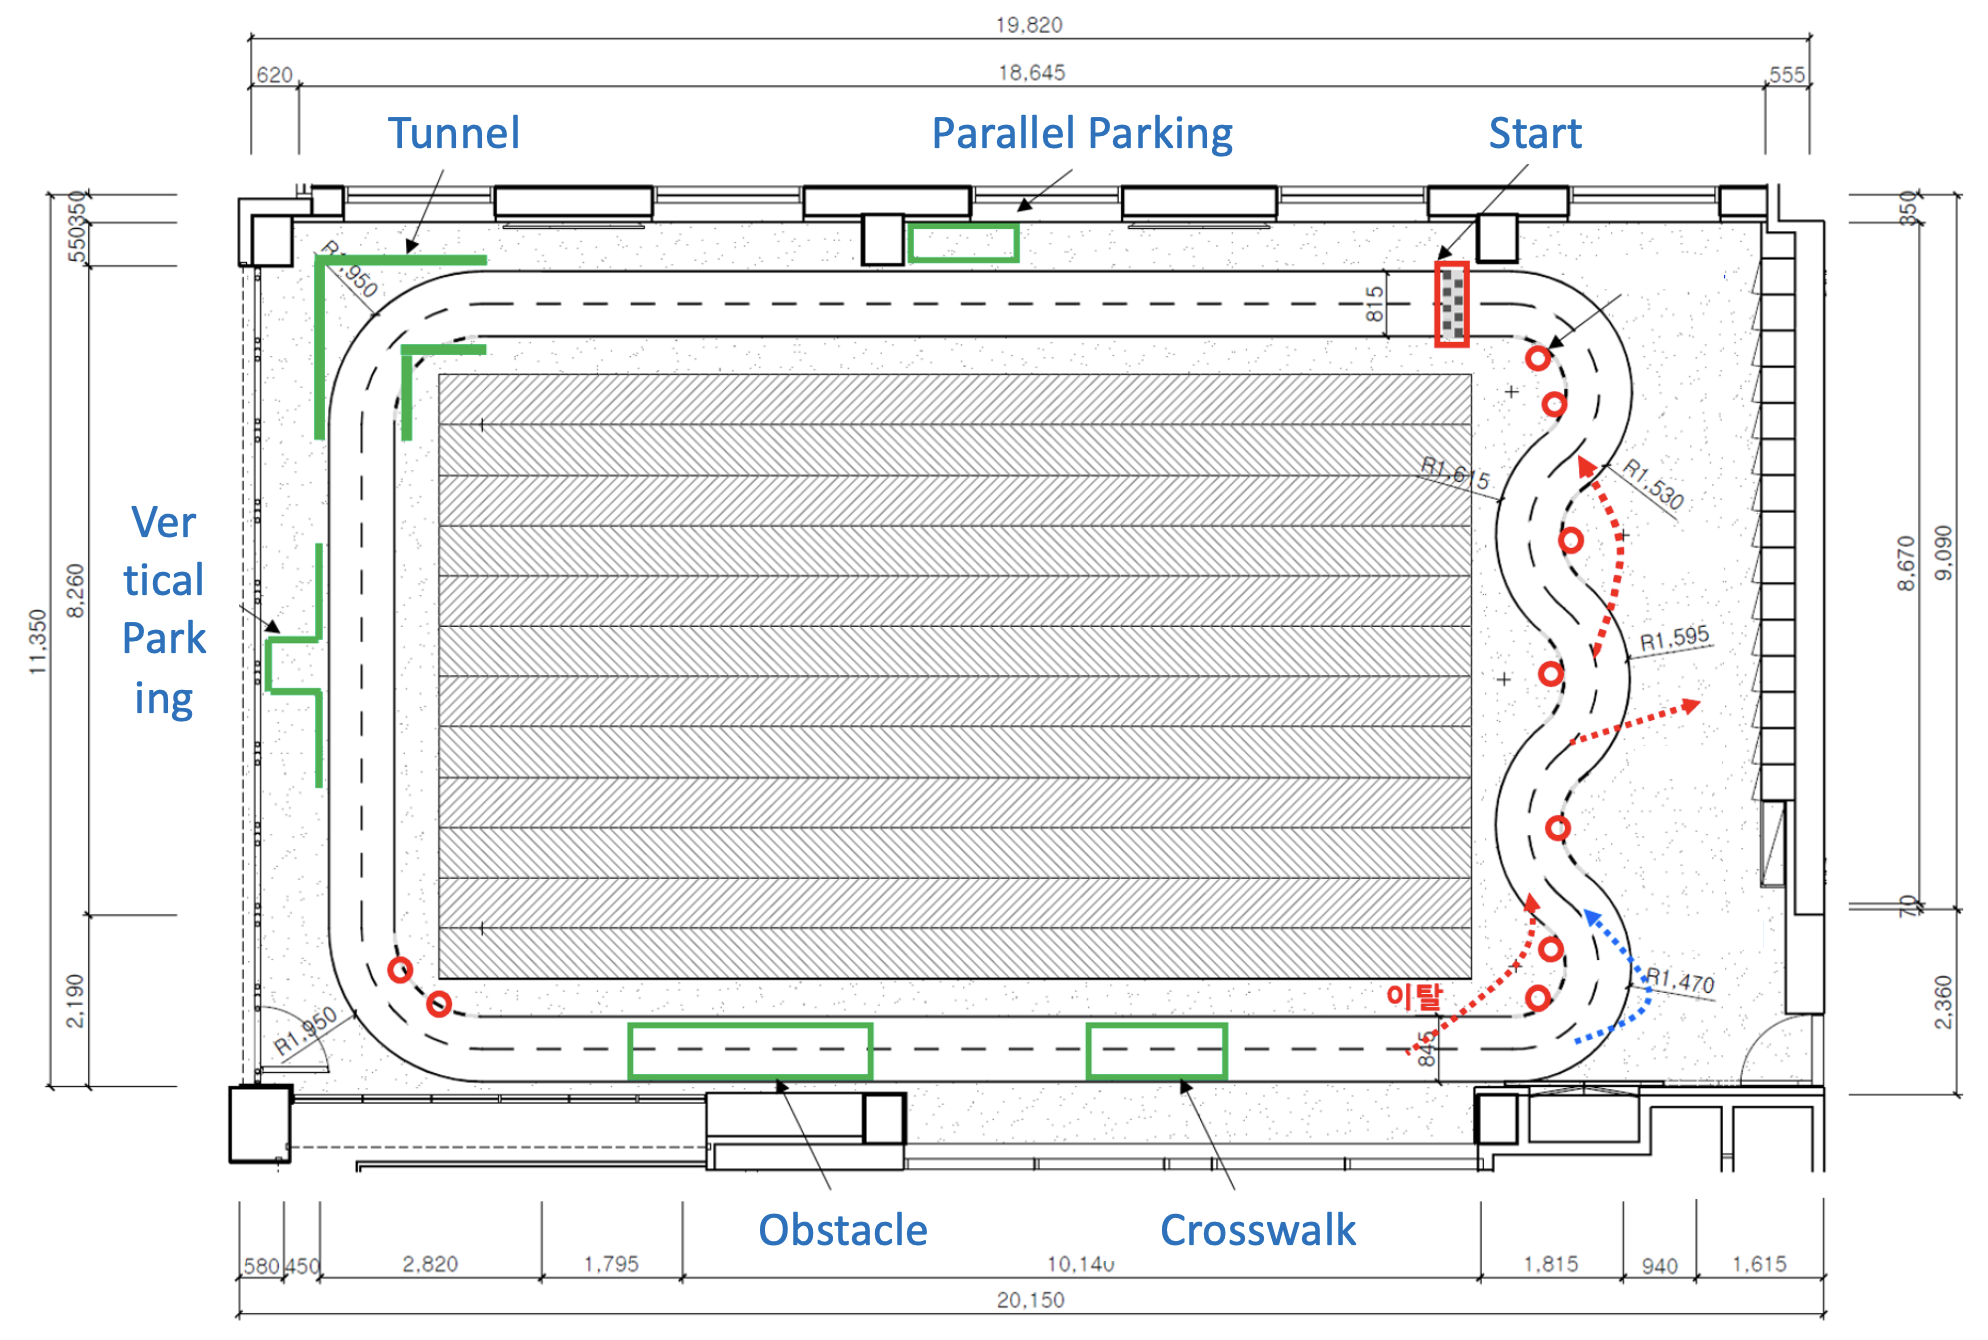
We developed a driver behavioural cloning model using CNN for end-to-end self-driving. However, if you aim to develop a model in the real environment, this code wouldn't be proper to use.
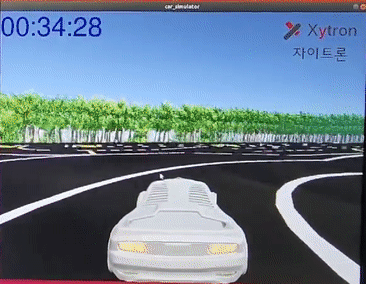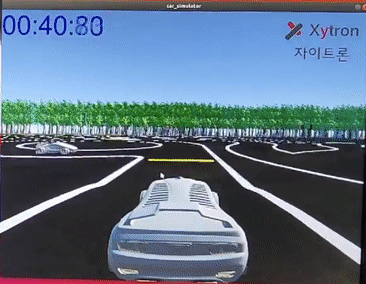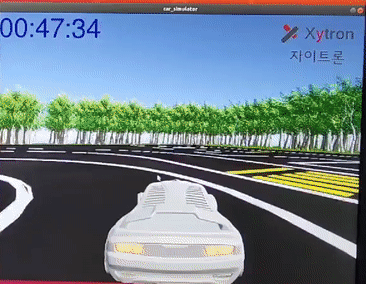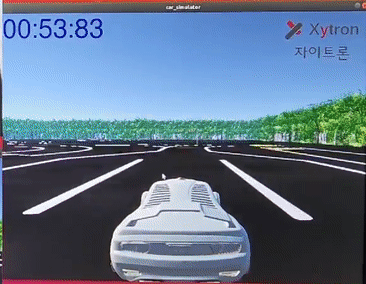
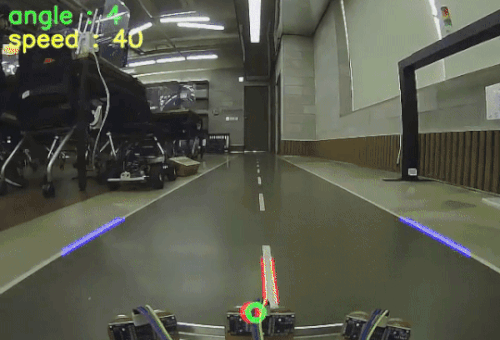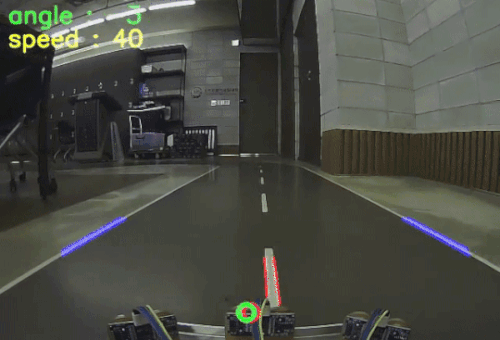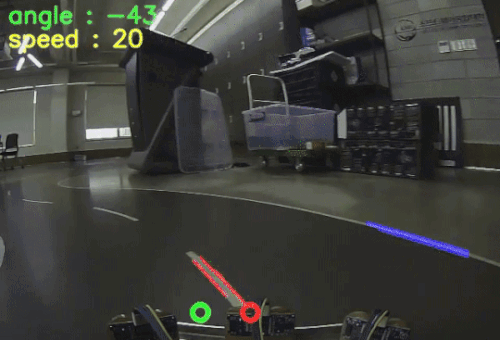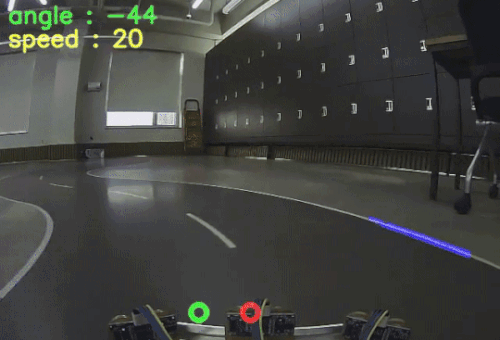
We performed image processing algorithms with OpenCV-Python for lane detection.