
This repo contains a PyTorch an implementation of semantic segmentation models. We refer to the original code (link) which implement basic SegNet.
This repository is developed by Taesoo Kim, and Junhee Lee.
We use Ubuntu 20.04. This project requires Python 3.8 and the following Python libraries:
- torch == 1.13.0
- numpy == 1.23.3
- tqdm == 4.32.2
- tensorboard == 1.15.0
- Pillow == 6.2.0
- opencv-python
To install the pacakges used in this repository, type the following command at the project root:
pip install -r requirements.txt- (SegNet) Basic SegNet
- A Deep ConvolutionalEncoder-Decoder Architecture for ImageSegmentation (2016): [Paper]
- (SegNet_L_Res) Basic SegNet + Local residual (intra VGGNet block)
- (SegNet_G_Res) SegNet_L_Res + Global residual (inter Encoder-Decoder)
- (SegNet_CReLU) SegNet_G_Res + CReLU (replace ReLU of Conv1,3,5 in Encoder)
- Understanding and Improving Convolutional Neural Networks via Concatenated Rectified Linear Units (2016): [Paper]
- (SegNet_Light_CReLU) Remove some part of SegNet_CReLU's encoder block
- (SegNet_LRR) SegNet_CReLU + Global_LRR(replace Global residual to LRR Mask Module)
- Laplacian Pyramid Reconstruction and Refinement for Semantic Segmentation (2016): [Paper]
- CityScapes: download from here
- CamVid: download from here
- BDD10k: download from here
- Mapillary Vistas: download from here
- Ours (Jeonju): if you need, please contact us. (without labeling)
- we modify all classes to the following palette:

To train a model, first download the dataset to be used to train the model, then choose the desired architecture, add the correct path to the dataset and set the desired hyperparameters (the config file is detailed below), then simply run:
python train.py --config config.jsonThe training will automatically be run on the GPUs (if more that one is detected and multipple GPUs were selected in the config file, torch.nn.DataParalled is used for multi-gpu training), if not the CPU is used. The log files will be saved in saved\runs and the .pth chekpoints in saved\, to monitor the training using tensorboard, please run:
tensorboard --logdir saved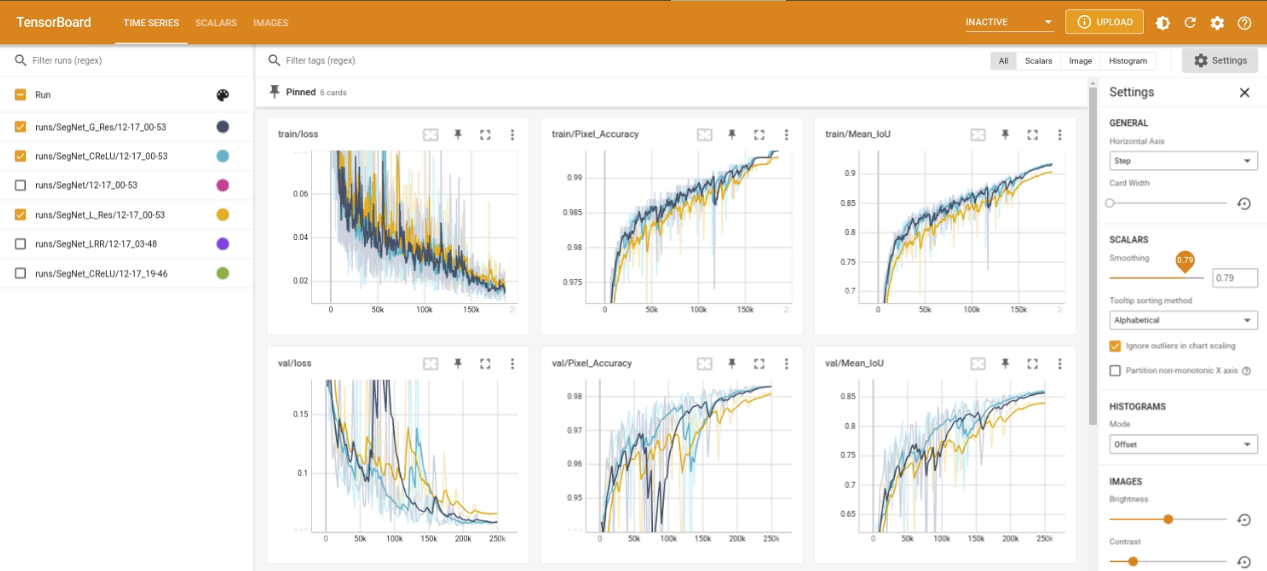
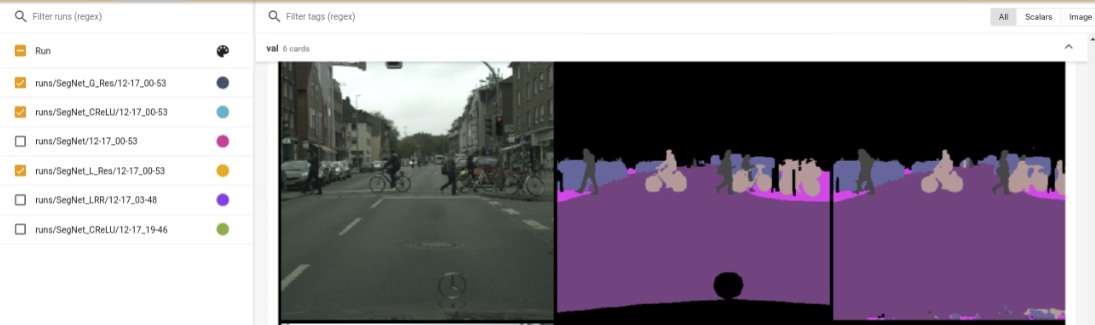
- Note: if you want to train & test SegNet_Light_CReLU, please replace the comment in SegNet_CReLU.py (from CreLU to Light CReLU) and use it with config3-1.json
For inference, we need a PyTorch trained model, the images we'd like to segment and the config used in training (to load the correct model and other parameters),
python inference.py --config config.json --model best_model.pth --images images_folderHere are the parameters availble for inference:
--output       The folder where the results will be saved (default: outputs).
--images       Folder containing the images to segment.
--model        Path to the trained model.
--config       The config file used for training the model.
Pre-Trained Model:
- Cityscapes Dataset
| Model | Backbone | val mIoU | inference time | Pretrained Model |
|---|---|---|---|---|
| SegNet (baseline) | VGG16 | 82.62% | 7.15it/s | saved/SegNet/best_model.pth |
| SegNet_L_Res | VGG16 | 83.99% | 6.99it/s | saved/SegNet_L_Res/best_model.pth |
| SegNet_G_Res | VGG16 | 85.73% | 6.68it/s | saved/SegNet_G_Res/best_model.pth |
| SegNet_CReLU | VGG16 | 85.99% | 6.44it/s | saved/SegNet_CReLU/original/best_model.pth |
| SegNet_Light_CReLU | VGG16 | 85.37% | 7.05it/s | saved/SegNet_CReLU/light/best_model.pth |
| SegNet_LRR | VGG16 | 84.77% | 6.06it/s | saved/SegNet_LRR/best_model.pth |
- Integrated Datasets (CityScapes, BDD10k, Mapillary Vistas, CamVid) -- in progress!
| Model | Backbone | val mIoU | Pretrained Model |
|---|---|---|---|
| SegNet_Light_CReLU | VGG16 | % | saved/SegNet_CReLU/best_model.pth |
- demo.py: Make video by simply running:
python demo.py --ip images_folder --op save_folder - demo2.py: Check the realtime inference time by simply running:
python demo2.py --config config.json --model best_model.pth --images images_folderautonomous-segmentation/
│
├── train.py - main script to start training
├── inference.py - inference using a trained model
├── trainer.py - the main trained
├── demo.py - make inferenced video with inferenced outputs
├── demo2.py - show realtime inference and visualization
├── config.json - holds configuration for training
│
├── base/ - abstract base classes
│ ├── base_data_loader.py
│ ├── base_model.py
│ ├── base_dataset.py - All the data augmentations are implemented here
│ └── base_trainer.py
│
├── dataloader/ - loading the data for different segmentation datasets
│
├── models/ - contains semantic segmentation models
│ ├── segnet.py
│ ├── segnet_l_res.py
│ ├── segnet_g_res.py
│ ├── segnet_crelu.py
│ ├── segnet_light_crelu.py
│ └── segnet_lrr.py
│
├── saved/
│ ├── runs/ - trained models are saved here
│ └── log/ - default logdir for tensorboard and logging output
│
└── utils/ - small utility functions
├── losses.py - losses used in training the model
├── metrics.py - evaluation metrics used
└── lr_scheduler - learning rate schedulers